

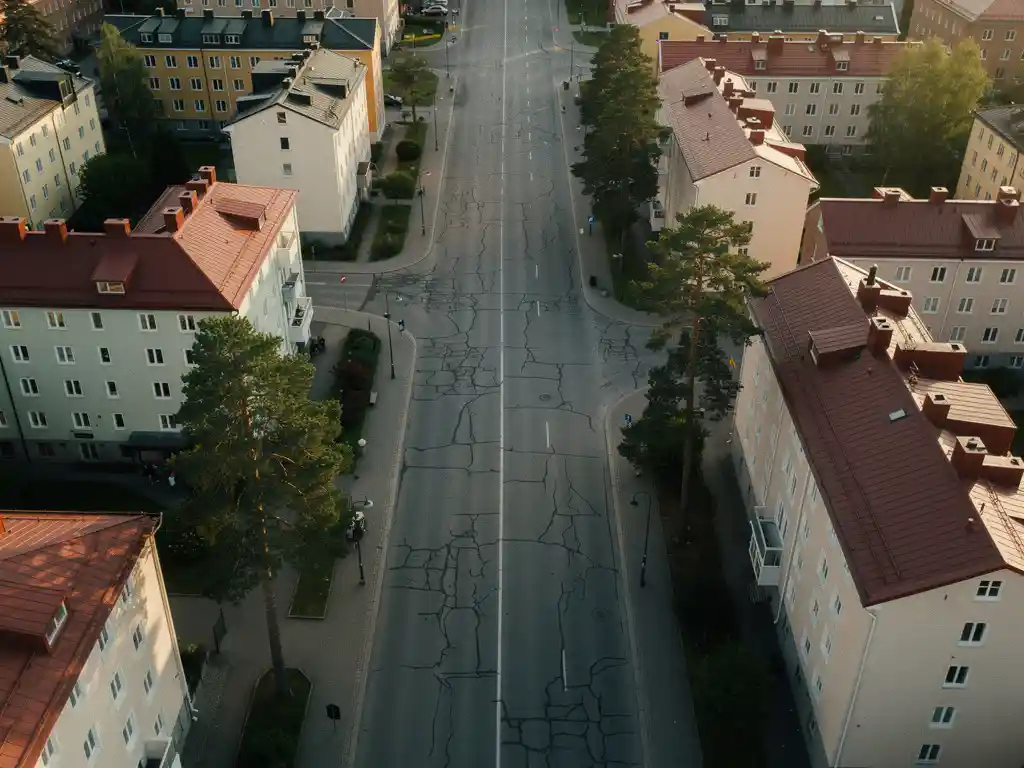
Autonomous vehicles use road surface data in real time by combining input from multiple onboard sensors, processing that data through AI algorithms in milliseconds, and translating the results into immediate driving decisions. The vehicle continuously scans the road ahead, identifies surface conditions, and adjusts speed, steering, and braking before a human driver would even register a hazard. The sections below unpack exactly how each part of that process works.
What types of sensors do autonomous vehicles use to read road surfaces?
Autonomous vehicles read road surfaces using a combination of LiDAR, cameras, radar, and ultrasonic sensors working together. Each sensor type contributes different data: LiDAR produces precise three-dimensional point clouds of the road geometry, cameras capture visual texture and color, radar detects the distance and speed of nearby objects, and ultrasonic sensors handle close-range measurements at low speeds.
LiDAR is particularly valuable for road surface detection because it measures the physical shape of the surface with millimeter-level accuracy, revealing elevation changes, depressions, and raised edges that indicate damage or obstacles. High-resolution cameras complement this by detecting visual cues such as cracks, lane markings, water reflections, and discoloration that suggest ice or oil.
Radar adds resilience in poor visibility conditions. Unlike cameras, radar performs reliably in heavy rain, fog, and darkness, making it a critical fallback when optical sensors are compromised. The fusion of all these inputs gives the vehicle a richer, more redundant picture of road surface conditions than any single sensor could provide alone.
How does an autonomous vehicle process road data fast enough to react safely?
Autonomous vehicles process road surface data fast enough to react safely by running dedicated onboard computing hardware that handles sensor fusion, object classification, and decision-making in parallel, typically within tens of milliseconds. The processing pipeline is designed so that safety-critical responses, such as emergency braking, are handled by low-latency dedicated circuits rather than general-purpose software loops.
The architecture generally separates perception from planning. The perception layer ingests raw sensor feeds and produces a real-time model of the environment, including road surface state. The planning layer then uses that model to calculate the safest trajectory. Because these layers run concurrently rather than sequentially, the vehicle does not need to finish a complete environmental scan before it can begin adjusting its behavior.
Modern AV platforms also use neural networks trained on vast libraries of road surface imagery and LiDAR scans. This training allows the system to recognize and classify surface conditions almost instantly, without needing to reason from first principles each time. The result is a reaction time that is consistently faster and more consistent than human perception, particularly for subtle hazards like early-stage surface deterioration.
What road surface conditions can autonomous vehicles detect?
Autonomous vehicles can detect a wide range of road surface conditions, including potholes, surface cracks, standing water, ice, loose gravel, rutting, uneven patches, and lane marking degradation. The combination of LiDAR geometry data and camera-based visual analysis allows the system to identify both physical deformations in the road surface and surface material changes that affect grip and traction.
Ice and wet surfaces are detected primarily through visual cues such as reflectivity patterns and color shifts, combined with radar signal behavior that changes when surfaces are wet. Potholes and cracks are identified through LiDAR point cloud anomalies that reveal depressions or irregular edges in the road plane.
The detection capability is not uniform across all conditions. Shallow cracks that have not yet caused surface deformation are harder to detect reliably from a moving vehicle than deep structural damage. This is one reason why dedicated infrastructure monitoring tools, such as the AI-powered road scanning solutions we develop at ScanwAi, complement AV sensor data by providing higher-resolution, systematic assessments of surface condition across entire road networks rather than just the path directly ahead of a single vehicle.
How does real-time road surface data influence AV driving decisions?
Real-time road surface data influences AV driving decisions by triggering immediate adjustments to speed, steering input, braking force, and route selection. When the vehicle detects a damaged surface or low-traction condition ahead, the decision-making system recalculates the safest trajectory and modifies vehicle behavior before the hazard is reached, not after contact with it.
Speed and braking adjustments
On detecting surface damage or reduced friction, the vehicle reduces speed preemptively and increases the following distance from other vehicles. Braking systems are primed to respond with less aggressive initial pressure to avoid skidding on compromised surfaces. These adjustments happen based on the predicted surface interaction, not just what the vehicle is currently driving over.
Steering and path planning
When a damaged area is identified in the vehicle’s planned path, the system can steer around it if lane width and traffic conditions allow. If avoidance is not possible, the vehicle adjusts its path to minimize the contact area with the damage and reduces lateral load on the affected wheel. Route-level decisions, such as selecting an alternate road, are made when the damage is severe enough to pose a safety risk that cannot be managed through in-lane adjustments.
How do autonomous vehicles share road surface data with infrastructure systems?
Autonomous vehicles share road surface data with infrastructure systems through vehicle-to-infrastructure (V2I) communication protocols, cloud-based data platforms, and standardized data formats that allow municipalities and road operators to receive aggregated condition reports in near real time. Each vehicle effectively acts as a mobile sensor contributing to a shared picture of road network health.
When a vehicle detects a significant road surface issue, the event data, including GPS coordinates, timestamps, sensor readings, and a severity classification, can be transmitted to a central platform where it is merged with data from other vehicles traveling the same route. This aggregation improves confidence in the detection and allows road operators to prioritize maintenance without sending inspection crews to every reported location.
The practical value of this data sharing depends heavily on standardization. Different AV manufacturers currently use proprietary data formats, which limits interoperability with municipal infrastructure management systems. Industry efforts to establish common data standards are ongoing, and as autonomous vehicle adoption grows in 2026, the volume and consistency of road condition data flowing into infrastructure systems are increasing significantly.
What are the biggest challenges in real-time road surface data processing for AVs?
The biggest challenges in real-time road surface data processing for autonomous vehicles are sensor performance in adverse weather, the computational cost of processing high-volume sensor data at low latency, variability in road surface types across different regions, and the difficulty of distinguishing temporary surface conditions from permanent structural damage.
Adverse weather is the most persistent challenge. Rain, snow, and ice simultaneously degrade the road surface and reduce the effectiveness of the sensors used to detect it. Cameras lose visual clarity, LiDAR returns become noisy from water droplets, and radar provides limited surface texture information. Sensor fusion helps, but no current system performs equally well across all weather conditions.
Computational load is a secondary constraint. Processing LiDAR point clouds, camera frames, and radar returns simultaneously at the frequency needed for safe driving requires significant onboard computing power. As sensor resolution increases and road networks become more complex, the processing demand scales accordingly. Managing this within the thermal and power limits of a vehicle is an ongoing engineering challenge, and understanding the key benefits of road scanning technology helps clarify why investment in this area continues to grow.
Finally, generalization across road types remains difficult. A system trained primarily on well-maintained urban roads may underperform on rural roads with different surface materials, edge conditions, and damage patterns. Building training datasets that reflect the full diversity of global road infrastructure is a long-term challenge for the entire autonomous driving industry, and one where systematic road condition monitoring at scale plays a supporting role in generating the ground truth data that AV systems need to improve. Road operators and municipalities looking to contribute to or benefit from this data ecosystem can get in touch with our road scanning team to explore how systematic surface assessments can support both infrastructure management and AV development.